





— Blogs —
—Products—
 Consumer hotline +8618073152920
WhatsApp:+8615367865107
Address:Room 102, District D, Houhu Industrial Park, Yuelu District, Changsha City, Hunan Province, China
Product knowledge
Time:2024-07-27 20:19:15 Popularity:6728
Ultrasonic sensors are widely used for non-contact distance measurement, object detection, liquid level monitoring and meteorological applications. They use high-frequency sound waves to detect targets or measure the propagation characteristics of sound through a medium.
Although ultrasonic sensors offer advantages such as non-contact measurement, relatively simple installation and compatibility with many industrial applications, they also have limitations. These include blind zones, weak acoustic reflections, environmental interference, beam-angle restrictions and measurement update-rate limitations.
The disadvantages of ultrasonic sensors depend on the sensor's measurement principle, construction and installation conditions. A pulse-echo ultrasonic distance sensor, for example, has different operating limitations from an ultrasonic anemometer that measures wind speed and direction using acoustic transit times.
This article examines the main limitations, their causes, practical solutions and situations in which alternative technologies may be more suitable.
The following table summarizes common limitations of pulse-echo ultrasonic distance and level sensors. Not every limitation applies in the same way to other ultrasonic sensing technologies.
| Limitation | Possible Effect | Practical Consideration |
|---|---|---|
| Blind Zone | Targets too close to the transducer may not be measured reliably. | Check the specified minimum measuring distance. |
| Temperature Variation | Changes in sound velocity can influence distance calculations. | Use suitable temperature compensation. |
| Weak Echoes | Soft, absorbent or angled targets may return insufficient acoustic energy. | Consider target material, orientation and sensing range. |
| Beam Spread | Nearby objects may produce unwanted echoes. | Check beam geometry and mounting clearance. |
| Acoustic Interference | Other ultrasonic devices or acoustic noise may disturb detection. | Use suitable spacing and signal filtering. |
| Environmental Contamination | Condensation, ice or deposits may weaken transmission and reception. | Inspect environmental protection and maintenance needs. |
| Update Rate | Some sensors cannot reliably detect very rapid target changes. | Compare response time and update frequency with the application. |
One important disadvantage of pulse-echo ultrasonic sensors is the presence of a minimum measuring distance, commonly called the blind zone or blocking distance.
In many pulse-echo designs, the same transducer emits an ultrasonic pulse and then receives its reflection. After transmission, the transducer requires a short time to stop vibrating and become ready to detect returning echoes.
If a target is too close, the reflected sound can return before the receiving system is able to evaluate it reliably. As a result, objects within the blind zone may not be detected correctly.
In tank level measurement, the liquid surface may rise into the sensor's blocking distance. In this condition, the sensor may report an invalid reading, lose its echo or activate a configured diagnostic response.
The blind-zone distance varies with the sensor design and model. It should never be estimated from the technology name alone.
Install the sensor so that the closest expected target remains outside its specified blocking distance. Check tank height, sensor mounting position, maximum liquid level and the manufacturer's measurement-range requirements.
Where very short-range detection is essential, select a sensor with an appropriate minimum detection distance or consider another measurement technology.
Ultrasonic measurement depends on the propagation of sound through a medium. Changes in the acoustic properties of that medium can affect measurement accuracy and signal strength.
The speed of sound in air varies with temperature. For a typical air-coupled pulse-echo distance sensor, distance is calculated using the measured acoustic travel time and an assumed or compensated sound velocity.
Distance = (Speed of Sound × Round-Trip Travel Time) / 2
If the actual speed of sound differs from the value used by the instrument, the calculated distance can contain an error.
Many industrial ultrasonic sensors include temperature compensation to reduce this effect. However, rapid temperature changes or temperature differences along the acoustic path may still influence results.
Humidity can affect acoustic propagation, although its influence on distance accuracy is often smaller than the effect of temperature under ordinary atmospheric conditions.
Changes in gas composition may have a more significant effect. A sensor calibrated for operation in air should not automatically be assumed to provide the same performance in a different gas environment.
Strong air movement or turbulence can disturb the propagation of ultrasonic waves. This may reduce echo quality or cause unstable readings in some distance-measurement applications.
Where possible, mount the sensor away from strong air jets, fans or turbulent flow paths. The appropriate solution depends on the sensor design and the physical installation.
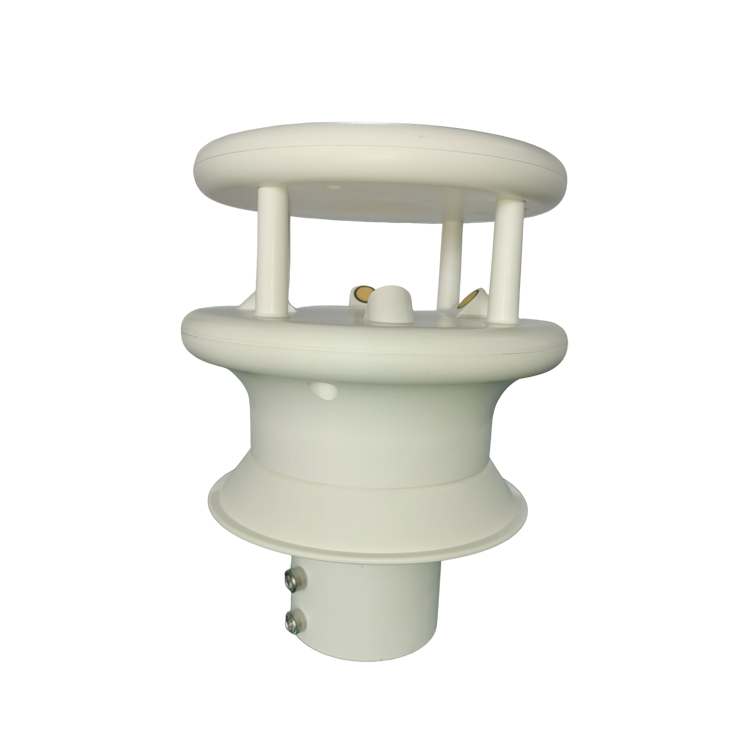
Pulse-echo ultrasonic sensors rely on the return of sufficient acoustic energy from the target. The target's geometry and acoustic properties therefore affect detection reliability.
Materials such as foam, certain fabrics and porous surfaces can absorb part of the incident ultrasonic energy. The return signal may become too weak for reliable detection, especially near the upper end of the sensor's measuring range.
A smooth surface can provide a strong reflection when it faces the sensor appropriately. However, if the surface is tilted, the reflected acoustic energy may travel away from the receiver.
This is important in applications involving inclined plates, moving objects, sloping material surfaces and certain liquid-level measurement arrangements.
Rough surfaces scatter sound in multiple directions. This may reduce the intensity of the returned echo and shorten the usable measuring range.
However, surface roughness is not always more problematic than a smooth inclined surface. The result depends on the surface geometry, ultrasonic wavelength and sensing arrangement.
Installation recommendation: Evaluate the target size, material, orientation and expected movement throughout the measurement range. For difficult targets, application testing is preferable to relying only on nominal sensor range.
Ultrasonic sensors generally transmit sound over a defined acoustic beam rather than along a perfectly narrow line. The beam can cover a wider area as the distance from the sensor increases.
When a sensor is installed inside a narrow tank, pipe or channel, its acoustic beam may strike nearby walls, structural supports or other obstacles. These reflections can produce additional echoes and interfere with the identification of the intended target.
Multipath occurs when sound reaches the receiver through more than one reflection path. A signal reflected from a wall or another object may arrive later than the direct echo from the intended target.
Depending on the sensor's processing algorithm, these signals may create false targets, unstable distance readings or reduced measurement confidence.
Check the manufacturer's beam diagram, avoid unnecessary obstacles within the detection area and follow the recommended sensor mounting geometry.
For ultrasonic level measurement, special attention should be paid to narrow vessels, mounting nozzles and internal tank structures.
Two or more ultrasonic sensors operating near each other may produce acoustic interference, sometimes called crosstalk.
If one sensor receives an ultrasonic pulse transmitted by another device, the received signal may be interpreted incorrectly. The risk depends on sensor frequency, positioning, measurement timing, distance and signal processing.

Use the minimum installation spacing specified by the manufacturer. Where the system supports it, synchronized triggering or sequential measurement can prevent nearby sensors from transmitting at the same time.
Acoustic crosstalk should also be distinguished from electrical interference on sensor power and signal wiring. Shielding and grounding practices help with electrical noise, but they do not necessarily eliminate interference caused by ultrasonic waves traveling through air.
Environmental conditions can affect ultrasonic measurement even when the sensor housing has a suitable environmental protection rating.
Heavy dust, rain, snow or airborne particles may attenuate or scatter an ultrasonic signal. Water droplets, accumulated dirt or ice on the sensing surface can also change the behavior of the transducer.
Minor contamination may have little effect on some sensor designs, while severe deposits or persistent condensation can cause incorrect readings or signal loss.
Select equipment with an appropriate operating temperature range, protection rating and installation design. Consider exposure to precipitation, icing, condensation, direct sunlight and maintenance access.
IP protection ratings describe defined enclosure protection characteristics. An IP rating alone does not guarantee uninterrupted acoustic measurement when ice, snow or water accumulates directly on the sensing surface.
Some ultrasonic sensors have slower measurement update rates than alternative technologies because acoustic pulses require time to travel to the target and return.
In pulse-echo measurement, the sensor must allow enough time to receive and evaluate a returning echo before starting another measurement cycle. Longer measurement distances generally require longer acoustic travel times.
Signal processing, averaging, filtering and noise rejection can further influence the effective response time.
For slowly changing tank levels, this limitation may have little practical significance. For high-speed object detection or rapidly changing production processes, response time can become a critical selection factor.
The actual update rate must be checked against the selected sensor's datasheet. Ultrasonic sensors do not all have the same response-time limitation.
Ultrasonic sensors require electronic circuitry to generate, receive and process acoustic signals. Their power requirements depend on the transducer, measurement interval, signal processing, communication interface and overall sensor design.
Some ultrasonic devices support low-power or intermittent measurements, making them suitable for battery-operated equipment. Other configurations require more continuous power.
Therefore, high power consumption should not be considered a universal disadvantage of ultrasonic sensing technology.
The same principle applies to cost. Ultrasonic sensors can be cost-effective in many non-contact applications, but the final system cost depends on measurement requirements, environmental protection, installation complexity and supporting equipment.
For solar-powered or battery-operated monitoring systems, evaluate the complete power budget, including the sensor, data logger, communication gateway and transmission schedule.
Not all ultrasonic instruments use the same measurement arrangement. Their practical disadvantages must be evaluated according to the intended application.
| Application | Main Considerations | Recommended Evaluation |
|---|---|---|
| Object Detection | Target dimensions, surface angle, blind zone, detection speed | Target compatibility and response-time testing |
| Tank Level Measurement | Foam, vapor, condensation, tank geometry, blocking distance | Echo reliability and installation geometry |
| Open-Channel Water Level | Water turbulence, foam, reflections and weather exposure | Mounting height, measuring range and environmental protection |
| Ultrasonic Anemometer | Transducer geometry, precipitation, icing and airflow disturbance | Model-specific wind performance and site exposure |
| Battery-Powered Monitoring | Startup, measurement cycle and communication energy | Complete system power-budget analysis |
Ultrasonic wind speed and direction sensors are commonly used in automatic weather stations. Unlike pulse-echo distance sensors, they typically measure the travel time of sound between transducers positioned along defined acoustic paths.
Wind affects the propagation time of ultrasonic signals in different directions. The instrument uses these differences to calculate wind speed and direction.
Consequently, the blind-zone limitation of a conventional pulse-echo distance sensor should not be applied directly to an ultrasonic anemometer.
For outdoor wind monitoring, important considerations include precipitation, icing, contamination, transducer positioning and the effects of the mounting structure on airflow.
NiuBoL offers the NBL-W-21MUWS ultrasonic wind speed and direction sensor, which provides digital wind measurements through RS485 communication.
For monitoring projects that also require atmospheric temperature, humidity and pressure, an all-in-one ultrasonic weather station may be considered.
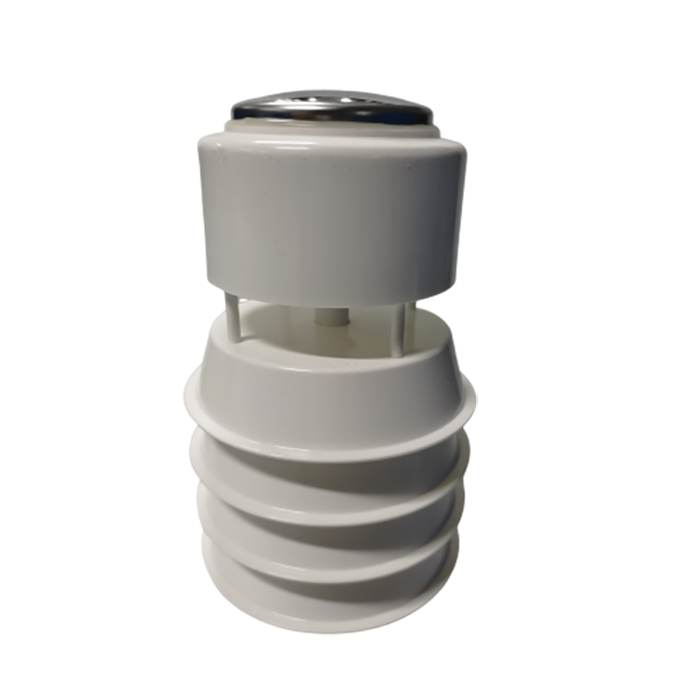
Ultrasonic and radar sensors are both used for non-contact measurement, but they operate using different physical principles.
Ultrasonic level sensors use acoustic waves, while radar level sensors use electromagnetic waves. This difference influences their responses to environmental conditions and the measured target.
| Comparison | Ultrasonic | Radar |
|---|---|---|
| Measurement Principle | Sound-wave propagation | Electromagnetic-wave propagation |
| Air Temperature Effects | Sound-speed changes may require compensation | Does not depend on acoustic sound speed |
| Gas Composition | May influence acoustic propagation | Generally less dependent on ordinary gas composition changes |
| Foam and Surface Conditions | Can absorb, scatter or alter reflected sound | Performance also depends on foam and target dielectric properties |
| Blind Zone | Model-specific blocking distance | Model-specific minimum measuring distance |
| Selection Criteria | Acoustic path, target reflection, environment and range | Target dielectric properties, antenna beam, environment and range |
Radar can be advantageous in applications involving changing air temperature, vapor or difficult acoustic propagation conditions. However, radar performance can also be affected by foam, condensation, antenna contamination and unwanted reflections, depending on the sensor design.
No measurement principle is universally superior. Select the sensor according to the actual process conditions, required accuracy, installation geometry and maintenance requirements.
For non-contact water and liquid level monitoring, explore the NiuBoL level sensor range, which includes different measurement technologies for hydrological and industrial applications.
Many ultrasonic measurement problems can be reduced through appropriate equipment selection, installation and maintenance.
| Observed Problem | Possible Cause | Recommended Action |
|---|---|---|
| No target detected | Target in blind zone or weak reflected signal | Check working distance and target orientation |
| Distance changes unexpectedly | Temperature changes or acoustic interference | Check compensation and surrounding conditions |
| Intermittent readings | Foam, condensation, contamination or weak echoes | Inspect the sensing surface and target conditions |
| False target detection | Unwanted reflections from nearby objects | Review mounting position and beam geometry |
| Nearby sensors interfere | Acoustic crosstalk | Increase spacing or use synchronized measurement if supported |
| Slow measurement updates | Acoustic travel time, averaging or processing delay | Check the sensor's stated update rate and filter settings |
If measurement problems continue, compare the sensor readings against a suitable reference under known conditions. Check the product manual for model-specific diagnostics, working distance, configuration and maintenance requirements.
A1: Common limitations of pulse-echo ultrasonic sensors include blind zones, sensitivity to weak or angled reflections, changes in acoustic propagation, unwanted echoes, acoustic interference and limitations on measurement update rates. Their significance depends on the application and sensor model.
A2: Many pulse-echo ultrasonic sensors need time to switch from transmitting to receiving. A very close target can return an echo before the receiving system is ready, creating a minimum measuring distance.
A3: Yes. Temperature influences the speed of sound in air, which can affect time-of-flight distance calculations. Temperature compensation reduces this error, but rapid changes or temperature gradients may still influence some measurements.
A4: Foam can absorb, scatter or reflect ultrasonic energy, depending on its characteristics. Thick foam may prevent reliable measurement of the underlying liquid surface. Application testing or an alternative sensing method may be necessary.
A5: Heavy precipitation, ice accumulation and contamination can interfere with acoustic transmission or reception. The actual effect depends on sensor design, installation and environmental protection.
A6: No. Radar can perform better in some difficult acoustic environments, but both technologies have application-specific limitations. Selection should consider the liquid or material, measurement range, foam, vapor, vessel geometry and installation conditions.
A7: Not generally. Ultrasonic anemometers commonly use sound transit-time measurements between transducers rather than measuring echoes returned from a distant target. Their primary limitations include transducer geometry, exposure conditions and model-specific wind measurement performance.
A8: Use suitable sensor spacing, avoid unwanted reflections and follow the manufacturer's mounting requirements. If supported, synchronized triggering or sequential measurements can reduce interference between nearby ultrasonic devices.
A9: Yes, when the selected instrument is designed for the expected environmental conditions. Protection against precipitation, icing, contamination and temperature extremes should be evaluated using the product's specifications and installation instructions.
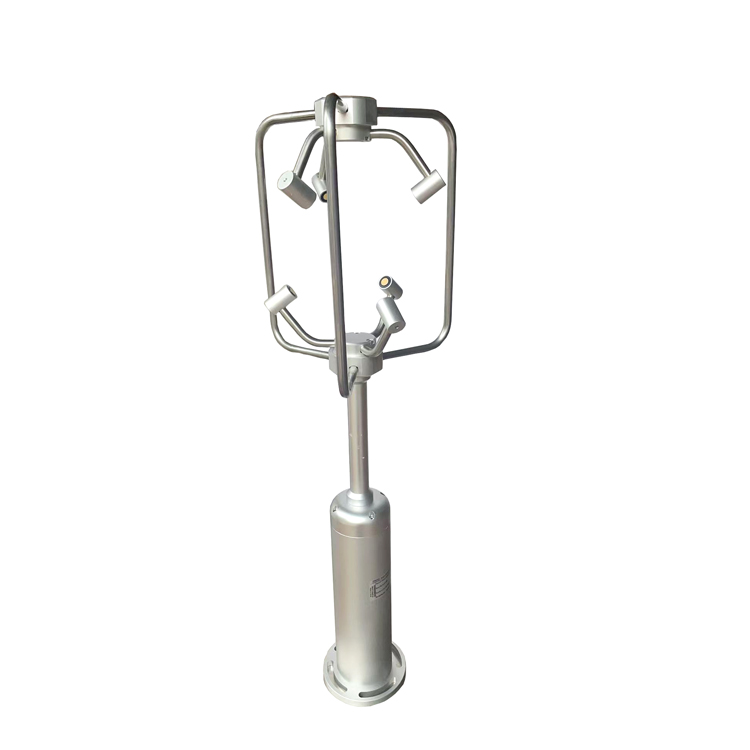
Ultrasonic sensors provide useful non-contact measurement capabilities, but their performance depends on acoustic propagation, target characteristics, environmental conditions and installation geometry.
For pulse-echo distance and level sensors, the most important limitations often include minimum measuring distance, weak reflections, unwanted echoes and environmental interference. Ultrasonic wind sensors use a different measurement arrangement and must be evaluated according to their own operating requirements.
Correct sensor selection requires checking the intended application, measurement range, target properties, environmental conditions, response time and integration requirements. In difficult applications, radar or another measurement technology may be more suitable.
NiuBoL provides weather monitoring equipment and level measurement sensors for agricultural, meteorological, hydrological and industrial projects. For equipment selection or system integration support, contact NiuBoL with your application requirements.
Related recommendations
Sensors & Weather Stations Catalog
 Agriculture Sensors and Weather Stations Catalog-NiuBoL.pdf
Weather Stations Catalog-NiuBoL.pdf
Agriculture Sensors Catalog-NiuBoL.pdf
Water Quality Sensor Catalog-NiuBoL.pdf
Related products
 Combined air temperature and relative humidity sensor
 TDR Soil Moisture & Temperature Sensor for irrigation| RS485 |4-20mA| NBL-S-THR
 Soil pH sensor RS485 soil Testing instrument soil ph meter for agriculture |NBL-S-PH
 Wind Speed sensor Output Modbus/RS485/Analog/0-5V/4-20mA
 Tipping bucket rain gauge for weather monitoring auto rainfall sensor RS485/Outdoor/stainless steel
 Pyranometer Solar Radiation Sensor 4-20mA/RS485


Screenshot, WhatsApp to identify the QR code
WhatsApp number:+8615367865107
(Click on WhatsApp to copy and add friends)

